Long-Range FPV and Racing Drones Need Different Antennas: Here's Why
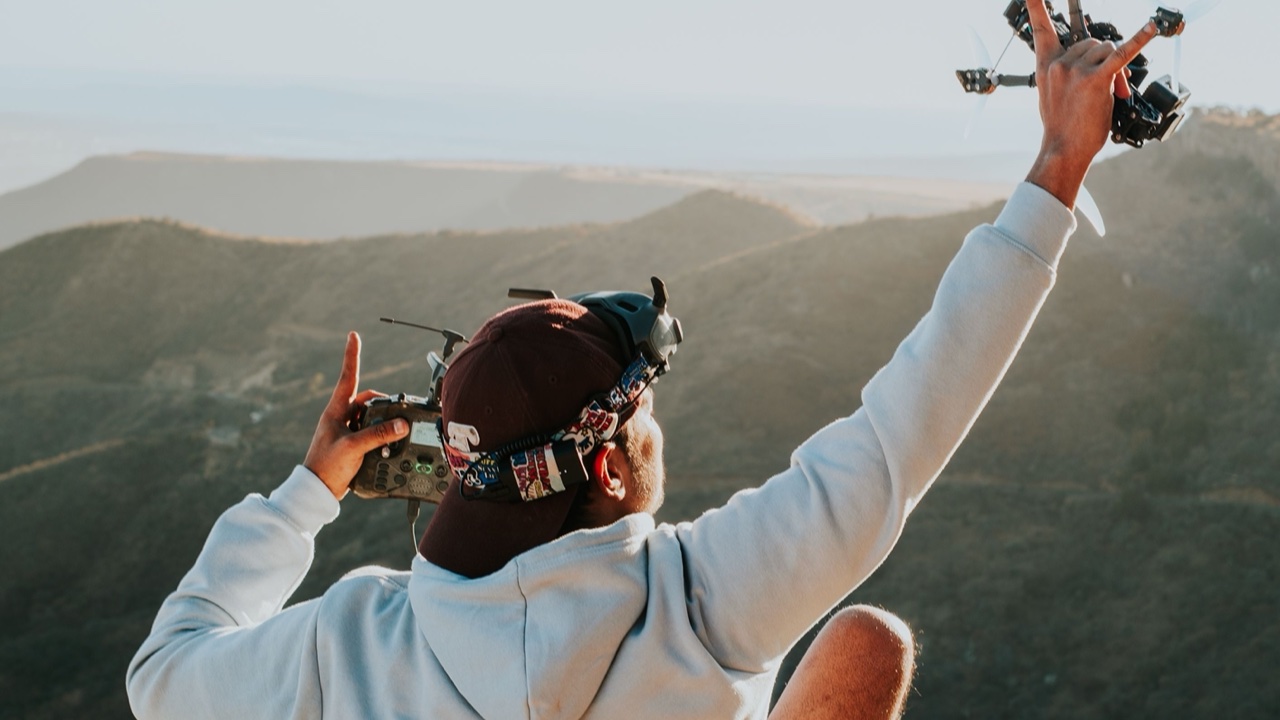
FPV flying covers a wide range of use cases that have almost nothing in common from an RF perspective. A pilot flying a 5-inch racing quad through a gate course at 30 meters range has completely different antenna requirements than someone cruising a fixed-wing aircraft to 10 kilometers over open terrain. Using the same antenna approach for both — which many pilots do, because they’re using the same frequency band and the same transmitter power — produces a system that’s suboptimal for one application or the other, and sometimes for both.
The antenna is where the trade-off between coverage pattern, range, and practical usability plays out. Understanding what each type of flying actually demands from the antenna system helps clarify why the choices that work for proximity flying often fail at distance, and vice versa.
What omnidirectional antennas actually cover
The term omnidirectional is frequently misunderstood in FPV contexts. An omnidirectional antenna doesn’t radiate equally in every direction — it radiates in a toroidal pattern centered on the antenna axis, with high gain in the horizontal plane and deep nulls directly above and below. For a vertically mounted 5.8 GHz antenna on a ground station, the high-gain plane is horizontal, which is exactly where most close-range flying happens.
The gain figure on an omnidirectional antenna — 2 dBi, 3 dBi, 5 dBi — represents how much signal is concentrated in the high-gain plane compared to an isotropic radiator. Higher gain means a flatter, more horizontal pattern. A 5 dBi omnidirectional has a narrower vertical beamwidth than a 2 dBi antenna, which means it covers a thinner horizontal slice of space with more signal — useful when the aircraft is always at approximately the same elevation as the ground station antenna, but problematic when the aircraft climbs steeply or is directly overhead.
For short-range proximity flying, the aircraft rarely leaves the high-gain zone of a reasonable omnidirectional antenna. The link margin at 30–100 meters is so large that pattern shape barely matters — there’s signal to spare in every direction. This comfortable margin leads pilots to treat their omnidirectional antenna as “good enough,” which it is, right up until they push to real distance.
Where omnidirectional antennas run out
The free-space path loss equation is not forgiving at distance. Every time the range doubles, path loss increases by 6 dB. An omnidirectional antenna system that works comfortably at 500 meters is operating with 18 dB less link margin at 4 kilometers than it had at 500 meters. For a 5.8 GHz system, that 18 dB is frequently the difference between a solid link and a video dropout.
Adding gain to the omnidirectional antenna helps — going from 2 dBi to 5 dBi adds 3 dB — but the gains are modest and come at the cost of vertical coverage. At some range threshold, no omnidirectional antenna has enough gain to maintain reliable link margin, and the system needs a directional antenna pointed at the aircraft.
The range threshold where this matters depends on the transmitter power, the receiver sensitivity, the frequency band, and what link margin is acceptable. At 5.8 GHz with 25 mW transmitter power — a typical FPV video transmitter — practical omnidirectional range to a reliable link is in the 1–3 kilometer range depending on conditions, aircraft altitude, and antenna quality. Beyond that, link dropouts become a question of when, not if.
Directional antennas and what they trade
Directional antennas solve the range problem by concentrating gain in a specific direction. A patch antenna with 10 dBi gain provides 8 dB more signal than a 2 dBi omnidirectional at the same range — equivalent to extending the reliable range by a factor of roughly 2.5 in free space. A high-gain Yagi at 14–16 dBi provides even more margin.
The trade-off is obvious: a directional antenna pointed at the aircraft provides gain only while the aircraft is within the antenna’s beamwidth. Turn away from the aircraft by more than the half-power beamwidth, and signal drops rapidly. For proximity racing, this makes a fixed directional antenna useless — the aircraft is constantly changing direction relative to the ground station, and no one is tracking the quad through gate courses by rotating a Yagi. For long-range cruise flying, particularly on a fixed-wing aircraft following a planned route, keeping the antenna pointed at the aircraft is feasible and dramatically extends the useful range.
Antenna tracker systems
The engineering solution that attempts to get directional antenna gain without manually pointing is an antenna tracker — a motorized mount that rotates the directional antenna to follow the aircraft’s GPS position. When it works, an antenna tracker running a high-gain patch or Yagi provides the range extension of a directional antenna with coverage that follows the aircraft automatically.
The practical complications are significant. An antenna tracker that relies on the aircraft’s GPS telemetry to know where to point has a dependency chain: if the video link degrades, the pilot may need to switch to a backup system, but if the tracker is pointing wrong during the transition, signal may be worse than it would be with a fixed omnidirectional. Trackers also have mechanical limitations — pan and tilt rate, home position behavior when signal is lost, initialization requirements — that add setup overhead and failure modes that don’t exist with a fixed antenna.
For pilots who fly long-range frequently and have a consistent operating area, the investment in an antenna tracker makes sense. For occasional long-range flying, the complexity often isn’t worth it, and a high-gain fixed directional antenna manually aimed at the aircraft’s intended flight path is a simpler approach.
Diversity systems as a practical middle ground
Most long-range FPV ground stations use a diversity receiver — two antennas connected to a receiver that selects whichever antenna has the better signal at any given moment. The classic configuration pairs one circular-polarized omnidirectional with one directional patch.
The omnidirectional handles the near-field, the overhead passes, and any direction the patch isn’t covering. The patch provides the gain needed for distance when the aircraft is in front of the ground station. The diversity receiver switches between them in real time, so the pilot doesn’t manually manage which antenna is active.
This configuration handles a wider range of flying scenarios than either antenna alone. It’s not optimal for maximum range — a steerable high-gain directional would outperform the patch at extreme distance — but it’s significantly better than an omnidirectional alone for distance flying, while still providing reasonable near-field coverage that a fixed directional can’t match.
The FPV Antennas used in diversity setups need matched connectors and compatible polarization between the omnidirectional and the patch elements. Mixing right-hand circular polarized and left-hand circular polarized antennas in a diversity pair introduces a polarization mismatch that degrades the performance of both, defeating the purpose of the diversity system. Both antennas should use the same circular polarization sense, with the polarization matched to whatever the aircraft is transmitting.
Practical range limits at 5.8 GHz
Regardless of antenna configuration, 5.8 GHz has physical range limits that come from the frequency itself. Higher frequencies attenuate more rapidly with distance, penetrate obstacles less, and are more sensitive to atmospheric conditions than lower frequencies. The long-range FPV community has largely accepted that reliable 5.8 GHz analog video beyond 5–6 kilometers requires either very high transmitter power (which creates regulatory issues in many jurisdictions), very high antenna gains on both ends, or accepting degraded but watchable video quality at the margins.
The emergence of digital FPV systems operating at lower frequencies, and the use of separate long-range control links at 900 MHz or 2.4 GHz alongside 5.8 GHz video, reflects the practical ceiling of what 5.8 GHz omnidirectional antenna systems can deliver. Pushing past that ceiling means accepting the complexity of directional antennas, antenna trackers, or frequency band changes — choices that are worth making for some use cases and not for others.